Krushna Jadhav · 3h 40m · 20 lessons
Gearbox design
Already know some of this? A 2-minute test skips the lessons you know.
Take the placement testThe plan
3 days at 90 min a dayDay 110 lessons · 1h 45mToday
- 1Gear Fundamentals: Pitch Circles and MeshingUnderstand gear teeth meshing, pitch circles, and how gears are modeled as rolling cylinders for kinematic analysis.11m Notes and quiz
- 2Torque Ratio Derivation via Free-Body DiagramsDerive the torque relationship T1/T2 = N1/N2 using free-body diagrams, tangent contact forces, and moment equilibrium.14m Notes and quiz
- 3Speed Ratio Derivation and Kinematic ConstraintsDerive the speed relationship ω1/ω2 = -N2/N1 from equal tangential velocities at the pitch point.9m Notes and quiz
- 4Winch Example: Spool Torque from Weight and UnitsCalculate spool torque from a 79 kg load, converting mixed units (inches, kg) to Newton-meters.11m Notes and quiz
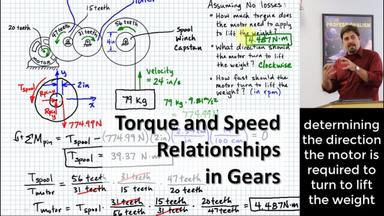
- 5Winch Example: Motor Torque Through Gear TrainTrace torque ratios through a 56-31-15-47-20 tooth gear train to find required motor torque (4.49 N·m), noting idler gear cancellation.9m Notes and quiz
- 6Torque and Speed Relationships in Gears | Motor Driving Winch Through Geartrain 8m Notes and quiz
- 7Factoring gear ratios into multi-stage reductionsLearn how to break down a large gear reduction into two stages by factoring the ratio and adjusting tooth counts to keep gears practical.6m Notes and quiz
- 83D Printing and Assembly ProcessLearn the 3D printing settings and step-by-step assembly procedure for the gearbox components.8m Notes and quiz
- 9Planetary Gearbox Overview and Kinematic DesignUnderstand the 4-stage planetary gearbox architecture, identify sun/planet/ring gear roles, and perform kinematic calculations for pitch diameters and tooth counts to achieve a 3:1 single-stage reduction.12m Notes and quiz
- 10Building a Single-Stage Epicyclic Gear Train in AssemblyCreate and mate sun, planet, and ring gears with correct gear ratios, add a carrier plate with pivoted planet shafts and bearings, and verify the 3:1 speed reduction via motion analysis.17m Notes and quiz